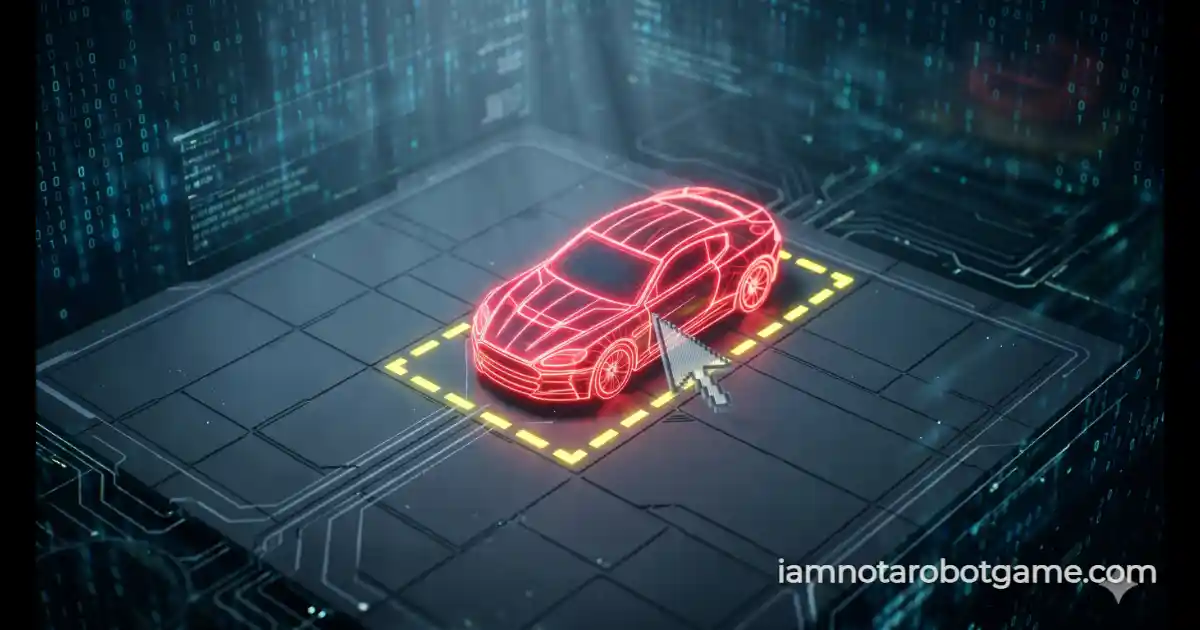
 Fig 1: The dynamic spatial bounding box verification matrix.
Understanding Spatial Bounding Box Verification
Welcome to Level 15: Parking. You have previously bypassed the inverted kinematic controls of Level 13: Reverse and survived the rigorous behavioral typing dynamics of Level 14: Affirmations. Now, the system evaluates a completely different cognitive domain: absolute spatial awareness. Level 15: Parking forces you to execute precise 2D translations to prove your organic origin.
Step-by-Step Spatial Parking Strategy
The verification arena renders an asphalt grid containing a moveable red car asset and a target yellow dashed parking bay. Because the initial and target coordinates are randomized on every initialization, spatial orientation must be calculated in real time. Execute this execution protocol to pass cleanly:
- Acquire the Vehicle Asset: Click and hold down the primary mouse button or touch interface directly over the red car. A slight scaling pulse indicates active grip.
- Navigate the Coordinate Matrix: Drag the vehicle smoothly across the grid toward the highlighted yellow parking slot. Maintain steady cursor contact to prevent accidental drop events.
- Align Geometry within Margins: Position the car precisely inside the bay. The system calculates continuous intersection bounding boxes upon release, requiring an 85% area overlap.
- Verify Coordinates: Release your pointer. If alignment is within tolerance, the vehicle snaps to the center, the success tone chimes, and you unlock Level 16: Now in 3D.
Why Spatial Drag Operations Defeat Automated Macros
In automated bot defense, spatial translation tasks exploit the rigid nature of simple coordinate macros and headless web scrapers:
- Randomized Spawn Coordinates: Both the starting position of the car and the target parking bay are generated dynamically on every session load using client-side randomization. Hardcoded coordinate clickers fail because target locations shift continuously.
- Continuous Pointer Kinematics: Successful completion requires a complete gesture sequence:
mousedown, a sequence of continuousmousemovecoordinates, and a concludingmouseuprelease. Simulating this multi-stage physical drag via script requires precise vector calculations. - Strict Geometric Intersection Thresholds: The backend calculates exact bounding client rectangles via DOM APIs. Falling even slightly short of the 85% overlap threshold triggers an immediate reset penalty.
Geometric Intersection Mathematics
Under the hood, the verification algorithm computes overlapping pixel rectangles across the X and Y axes upon pointer release. This mathematical rigor guarantees that only authentic human spatial judgment can clear the obstacle.
Mastering this 2D plane coordination is essential preparation for the volumetric depth challenges waiting in Level 16: Now in 3D.
Frequently Asked Questions
How do I beat the Parking level?
You must drag and drop the vehicle perfectly into the highlighted parking spot. The vehicle's bounding box must overlap the target by at least 85%.
Why does the car reset when I drop it?
If your drop coordinates fail the 85% overlap threshold, the system flags the attempt as a miscalculation and snaps the vehicle back to the starting point.
Can an automated script pass this test?
Simple coordinate macros fail because the exact starting and target positions randomly generate on every load, preventing blind scripting.
Is this level harder on mobile devices?
Mobile devices utilize touch events, which can obscure the target beneath your finger. We recommend using a stylus or careful edge-dragging for precision.